Print the parts
The seven printed parts of the Mk3, the current Mechanism, and how to print them. Next: assemble them.
The presentation of the Mk2, the previous Mechanism (50 s, 3D animation).
The parts
The Mk3 is the current Mechanism. It is standalone: the board and the power boards fit inside the robot, in the clamp's technical cavity closed by a printed door, and a single USB-C connector powers it. All files are in stls/mk3/, and catwandconnect-mk3.3mf contains the whole plate.
| Part | File |
|---|---|
| Arm | catwandconnect-mk3-arm.stl |
| Bearing holder | catwandconnect-mk3-bearing_holder.stl |
| Clamp | catwandconnect-mk3-clamp.stl |
| Door | catwandconnect-mk3-door.stl |
| Screw | catwandconnect-mk3-screw.stl |
| Rotor plate | catwandconnect-mk3-rotor_plate.stl |
| Top plate | catwandconnect-mk3-top_plate.stl |
What changed from the Mk2: the electronics move inside the robot, behind the new door, and the robot needs only one USB-C cable.
Previous Mechanism: Mk2
The Mk2, reinforced with a 608 skateboard bearing and a track of 4 mm steel balls, leaves the electronics outside the robot. Pick it if you'd rather keep the board and the power boards outside. Its six parts are in stls/mk2/, and catwandconnect-mk2.3mf contains its whole plate.
Print recommendations
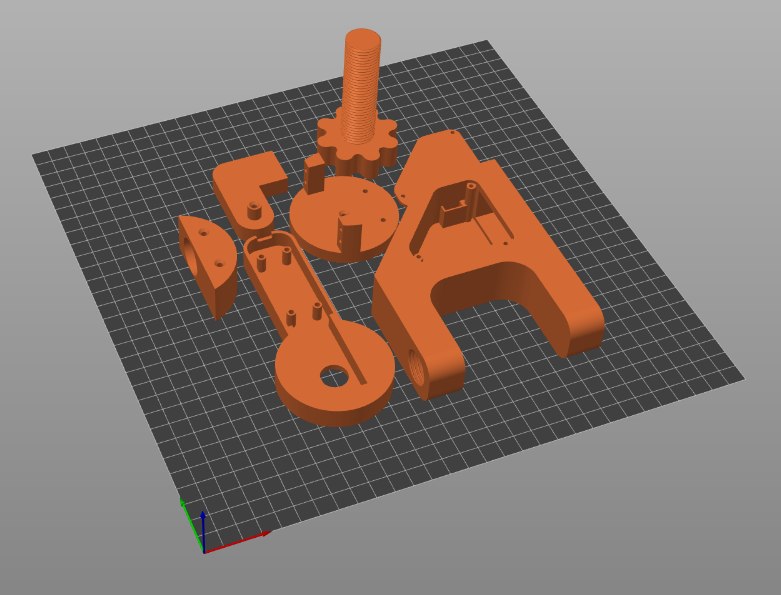
Starting points, not yet checked against the reference build. Share the settings that work for you on Discord and they will land here.
- Material: PLA works for a robot that stays indoors; PETG is tougher if the cat attacks the arm.
- Supports: none, except on the clamp. Print every other part, door included, without supports. The clamp needs supports under its horizontal surfaces only: in PrusaSlicer, turn on supports with an overhang threshold of 5° so they don't fill its slopes and holes.
- Strength: 3 walls or more and 20–30 % infill. The arm, the clamp and the parts that hold the servos take the load.
- Ball track: print it flat with a fine first layer, and clean any strings or elephant's foot so the balls roll freely.
- Fit: if the bearing or a servo doesn't go in, sand the part rather than force it.
- The
.3mfholds the whole plate in one file.
A printed part breaks? Reprint it: that is the point of an open design.
Next: Assemble the Mechanism.